4K // LIVE
The seven competitions // Full rulebook

Seven real-world tests. Seven world titles.

Four-arm autonomous robot crossing a P.AI Games multi-trial technical arena
TRIALS OPENING FEED

These are the seven competitions of the world's first real-life Robogames: load a dishwasher without a single break, open three doors the robot has never seen, paint a wall with live sockets exposed, fold fifteen mixed garments, haul wet refuse to a street cart, assemble flat-pack furniture, and cross an unseen obstacle trail that proves SLAM and secure navigation. Each competition pays US$100,000 to the winner, US$10,000 for second and US$5,000 for third. Declared teleoperation is allowed in the inaugural Games, with a transparent deduction applied to the final score; undisclosed human input remains a violation. Every rule, measurement and instant-disqualification condition is published here and in the downloadable rulebook — no simulations and no second attempts.

CAM 01

7 HOSTILE TESTS

CAM 02

SLAM GAUNTLET

CAM 03

0.25MM COATING SCAN

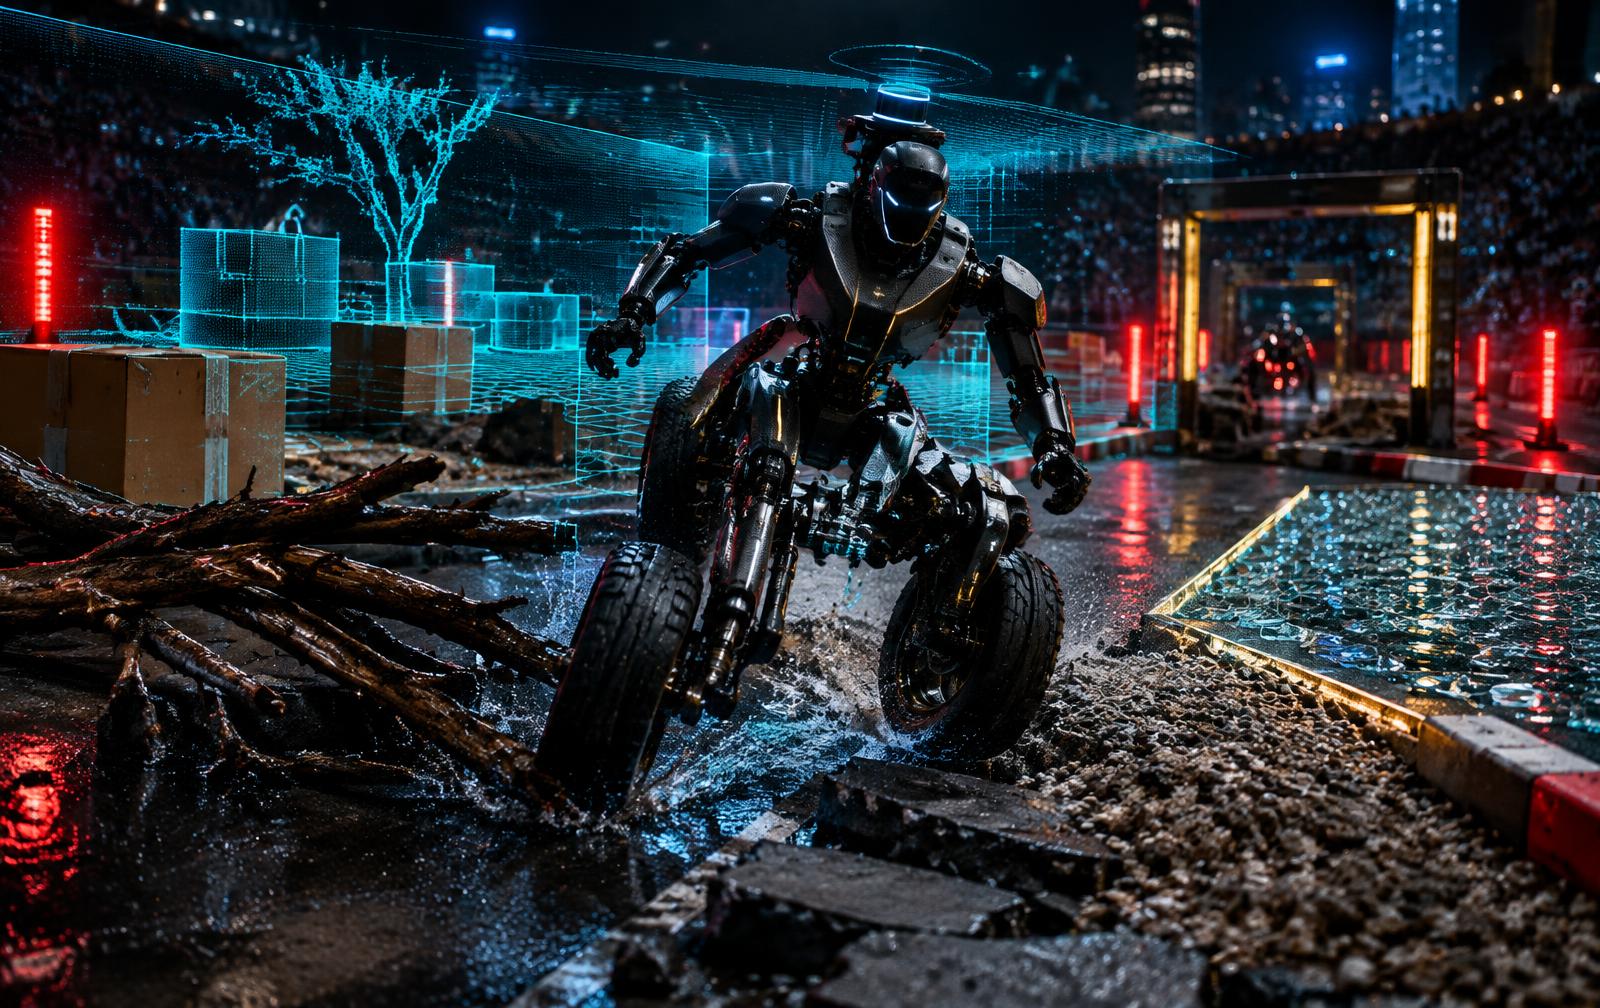
Rugged competition robot crossing the SLAM Gauntlet obstacle trail with cyan mapping grids
Trials visual feed // Unseen SLAM trail

The course is unknown until the gate opens.

The seventh competition adds a street-like gauntlet of boxes, tree branches, broken pavement, gravel, glass-debris zones and narrow gates. Teams must prove real-time mapping, localization and secure path planning under the same F1 cybernetic race language.

VISUAL FEED 01

NO PRIOR MAP

VISUAL FEED 02

GLASS HAZARD ZONE

VISUAL FEED 03

SAFE SPEED WINS

Official documents // Controlled release

Download race control packs.

Formal downloadable assets for teams preparing compliance binders, arena rehearsals, freight filings, and technical briefings.

Official Rulebook v1.1 [PDF]

The complete operational manual: 14 articles covering entry, paddock, technical limits, scrutineering, run procedure, scoring, penalties, protests, safety, freight and IP, plus seven trial sheets and the full three-day timetable.

PDF // 23 PAGES // V1.1

Download PDF

CAD / Blueprint Briefs

Arena dimensions, sensor positions, obstacle-class references, object datum packs, forbidden volumes, and inspection reference sheets, including the unseen SLAM obstacle-trail envelope.

PDF // 7 PAGES // V1.1

Download CAD Pack

Autonomy Safety Charter

Emergency stop design, battery containment, RF discipline, spectator protection, declared control modes, and the final-score deduction for teleoperated runs.

PDF // 4 PAGES // V1.1

Download Charter

Telemetry Schema

Required timing, torque, temperature, power, and autonomy signals for official broadcast overlays.

PDF // 2 PAGES // 5 KB // V1.0

Download Schema
Control-mode scoring // Inaugural Games

Teleoperation can compete—with a deduction.

Autonomous, supervised teleoperation and hybrid entries may run in the first championship. Each team declares its control mode before the start. The AI referee records the raw task result first, then applies the published teleoperation deduction to the final score. Undisclosed operator input remains a violation and may invalidate the run.

Seven disciplines // Engineering sheets

Full technical challenge matrix.

01
T-01 // DISHWASHER LOADING RACE SHEET 01

THE PORCELAIN PROTOCOL

Load a mixed domestic service into competition dishwashers without fracture, collision, or excessive acoustic impulse.

Clock
08:00
Primary sensor
Tactile fingertips + micro-slip
Scoring vector
Handling fidelity
Red flag
Instant DNF
Arena specification
  • 6m x 6m kitchen cell with calibrated counters, three rack geometries, wet grip contamination, and randomized object ordering.
Hardware and manipulation constraints
  • Crystal stems, thin porcelain plates, saucers, bowls, greasy flatware, mugs, and uneven glass tumblers
  • Tactile fingertips and micro-slip recovery permitted
  • No preloaded dishwasher brand maps; teams receive rack geometry at gate open
Scoring matrix
  • +10 per item loaded in a valid rack position
  • -50 for any dropped item, rack collision that dislodges ware, or tool impact
  • Tie-breakers: lowest peak grip force, lowest rack-contact impulse, fastest valid completion
Disqualification trigger

Acoustic instant DNF for any breakage impulse above 85dB or visible fracture propagation.

CAD / blueprint brief

Dishwasher rack CAD, counter height datum, acoustic sensor position map

02
T-02 // THREE UNMAPPED DOORS RACE SHEET 02

THE THRESHOLD BREACH

Pass three previously unseen architectural barriers using non-destructive manipulation and adaptive force planning.

Clock
06:30
Primary sensor
Torque feedback + 3D kinematics
Scoring vector
Adaptive planning
Red flag
Instant DNF
Arena specification
  • Sequential corridor with a hydraulic commercial glass door, a steel security door with rotary deadbolt, and a 60kg sliding panel.
Hardware and manipulation constraints
  • Glass door: 45N spring resistance and damped close profile
  • Steel door: rotary deadbolt, lever handle, latch friction variance
  • Sliding panel: 60kg mass, recessed pull cavity, floor-rail contamination
Scoring matrix
  • +150 for each threshold cleared without contact damage
  • +40 for verified sub-limit torque control
  • Penalties for handle over-rotation, casing strikes, or unnecessary re-grips
Disqualification trigger

Zero-structural-damage mandate: frame displacement, lock jam, cracked glass, or panel derailment ends the run.

CAD / blueprint brief

Door-frame datum sheets, deadbolt torque envelope, panel rail profile

03
T-03 // THE LIVE WALL RACE SHEET 03

PRECISION COATING

Coat a wall with roller and brush near live-style hazards while maintaining thickness uniformity and clean edges.

Clock
12:00
Primary sensor
Viscosity flow + edge segmentation
Scoring vector
Edge precision
Red flag
Instant DNF
Arena specification
  • 3m x 2.5m drywall segment with raw open AC socket terminals, bare glass insert, skirting lip, and corner edge discontinuities.
Hardware and manipulation constraints
  • Zero-tape rule: no masking, stencil, adhesive shield, or pre-fitted barrier
  • Laser spectrophotometer scan targets 0.25mm coating thickness
  • Paint tray location randomized inside tool zone
Scoring matrix
  • Thickness score centered on 0.25mm target with variance penalty
  • +120 for glass-edge tolerance under 2mm
  • Negative score for streaking, wall voids, roller shedding, or floor droplets
Disqualification trigger

Immediate DNF on tool, liquid, appendage, or overspray contact with exposed terminals.

CAD / blueprint brief

Drywall elevation, terminal no-contact boxes, spectrophotometer scan lattice

04
T-04 // TEXTILE ORIGAMI RACE SHEET 04

THE DEFORMABLE MATRIX

Identify, orient, fold, and stack fifteen disordered garments with bimanual manipulation under occlusion.

Clock
09:00
Primary sensor
Bimanual mesh-state tracking
Scoring vector
Deformable control
Red flag
Instant DNF
Arena specification
  • Textile bench with randomized pile state, visual clutter, five fabric classes, and calibrated final stacking plinth.
Hardware and manipulation constraints
  • 15 mixed unorganized garments: denim, towels, stretch socks, woven shirts, and elastic athletic tops
  • Dual-arm bimanual criteria: both manipulators must participate in orientation or fold locking
  • 90-degree stack stability test applied after timer stops
Scoring matrix
  • +80 per garment folded to class-specific template
  • +100 for stack passing 90-degree stability rotation
  • Seam alignment tolerance: 8mm for shirts, 12mm for towels, 15mm for denim
Disqualification trigger

Dropped garment outside textile zone, tear damage, or final stack collapse before stability release.

CAD / blueprint brief

Garment template pack, seam tolerance gauge, plinth rotation axis

05
T-05 // URBAN LOAD & DISPOSAL RACE SHEET 05

THE HEAVY HAUL

Extract wet refuse, transfer it to a municipal container, descend a curb, and clear an urban obstacle track.

Clock
07:30
Primary sensor
Whole-body balance + live COG
Scoring vector
Dynamic stability
Red flag
Instant DNF
Arena specification
  • Service alley lane with curb drop, textured ramp, uneven expansion joints, and liquid spill detection grid.
Hardware and manipulation constraints
  • 12kg thin-film wet refuse extraction from narrow bin liner
  • 240L municipal wheeled container with asymmetric load distribution
  • Obstacle track includes curb descent, surface seam, debris chicane, and parking stop
Scoring matrix
  • +250 for intact bag extraction and valid container placement
  • +150 for controlled curb descent without container tip
  • Energy and center-of-gravity smoothness used as ranked tie-breakers
Disqualification trigger

Bag tear, detected liquid spill, container overturn, or safety boundary breach.

CAD / blueprint brief

Curb geometry, container centerline, spill matrix sensor coordinate file

06
T-06 // MECHANICAL JOINERY RACE SHEET 06

UNBOX & ASSEMBLY

Unbox heavy-duty cardboard packaging, identify modular joinery, assemble with calibrated torque, and survive load testing.

Clock
14:00
Primary sensor
Micro-dexterity + force control
Scoring vector
Assembly integrity
Red flag
Instant DNF
Arena specification
  • Assembly bay with shipping carton, hardware packets, flat-pack members, driver bits, and pneumatic validation press.
Hardware and manipulation constraints
  • Heavy-duty cardboard unboxing without blade incursion into internal parts
  • Modular flat-pack joinery with mixed fastener types and asymmetric panels
  • Power driver torque calibration required before first fastener
Scoring matrix
  • +100 for packaging removal and part identification
  • +300 for complete square assembly
  • +200 for passing final 20kg pneumatic press stress test
Disqualification trigger

Dropped fastener into forbidden zone, stripped fastener head, structural misassembly, or stress-test failure.

CAD / blueprint brief

Exploded joinery pack, torque calibration curve, press contact footprint

07
T-07 // UNSTRUCTURED TRAIL NAVIGATION RACE SHEET 07

THE SLAM GAUNTLET

Cross a previously unseen outdoor-style route as fast and safely as possible while building a live map, localizing continuously, and choosing secure paths through clutter, unstable footing, and visual hazards.

Clock
10:00
Primary sensor
SLAM + terrain perception
Scoring vector
Safe speed navigation
Red flag
Instant DNF
Arena specification
  • 18m x 6m variable trail with unopened route geometry until gate release, mixed pavement breaks, curb transitions, cardboard boxes, tree branches, planters, gravel patches, reflective glass fragments, loose debris, and narrow passage gates.
Hardware and manipulation constraints
  • No prior course map, fiducial tape, GPS beacon, or human spotter guidance after the run begins
  • Robots may use onboard LiDAR, depth cameras, radar, inertial sensing, wheel odometry, tactile bumpers, and proprioception
  • Obstacle layout changes between heats so teams must demonstrate real SLAM, relocalization, and dynamic path planning
Scoring matrix
  • Fastest safe crossing wins after safety penalties are applied
  • +200 for clean autonomous map completion with loop-closure confidence above the published threshold
  • +100 for secure traversal of broken pavement, glass-debris zone, and narrow-gate section without wheel slip, foot strike, or obstacle displacement
Disqualification trigger

Immediate DNF for leaving the marked corridor, contacting broken-glass hazard with an unprotected actuator, tipping, dragging a major obstacle more than 20cm, or accepting undisclosed human navigation input.

CAD / blueprint brief

Trail boundary envelope, obstacle-class catalogue, glass hazard exclusion map, loop-closure scoring protocol